A quarry rover.
With a drill—not as a drill.
S01 is a reversible autonomous excavator and feedstock courier. Opposed bucket drums move bulk loose material; the removable BorePod handles the jobs boring is actually good at.
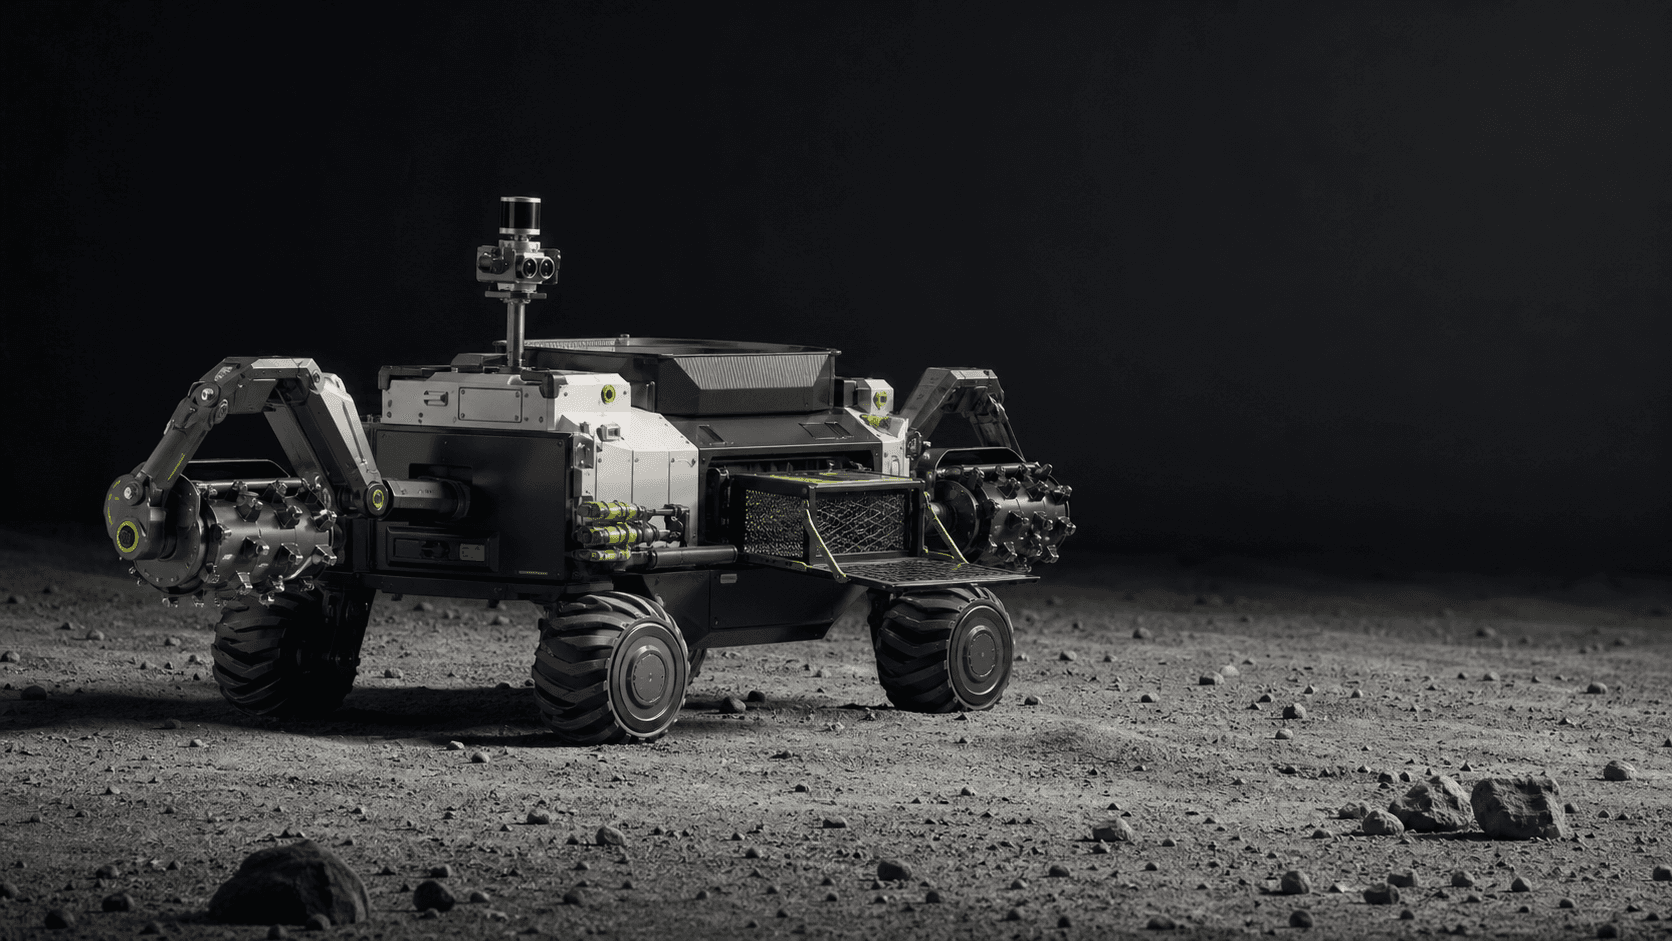
Swovee Scoop
Surface Harvester + BorePod + Prep Dock
ENGINEERING TARGETS · NOT A FLIGHT-PROVEN PRODUCTThree modules. One material passport.
Opposed bucket drums
Two hollow drums cut in opposite directions so most horizontal reaction cancels. Articulated arms make shallow skim cuts, lift the captured load and reverse to unload.
- Replaceable carbide or hard-faced lips
- Internal baffles for haul retention
- Sealed drives and labyrinth dust paths
- Torque-balanced depth control
Rotary-percussive cassette
A belly-stowed lance bores in instrumented 100 mm increments for hardpan, ice-cemented soil, samples and geotechnical ground truth.
- 60–100 mm interchangeable heads
- 1 m target depth
- Torque, thrust, vibration and temperature
- Arms plant as reaction feet
Classify before release
A stationary compliant hopper weighs each load, rejects rocks, screens to the selected recipe and seals the accepted batch into the Forge.
- Scalping grate before any auger
- Replaceable screen cassettes
- Separate fines, product and oversize bins
- No crusher in the first baseline
Sized to be engineered—not imagined.
These are A0 design targets for an Earth demonstrator and mission trade studies. NASA subsystem heritage supports plausibility, but Swovee must earn every number in representative simulant, dust, vacuum and reduced gravity.
From quarry cell to qualified feed.
Bore selected cells; classify loose, hardpan, volatile-sensitive, obstacle or prohibited ground.
Servo shallow passes while fore and aft drum torque remain balanced.
Infer payload from arm loads and calibrated lift current; stop at the ordered batch mass.
Raise the drums, verify clearance and travel along the approved energy-safe route.
Use LiDAR, fiducials and a compliant funnel; reverse the drums into P01.
Accept only material that passes mass, grading, composition and contamination rules.
Jams are a design case.
Drum torque imbalance + chassis pitch
Lift the overloaded arm, reduce advance and re-enter with a shallower cut.
Current spike + arm load + stereo change
Stop, reverse, map a keep-out and route oversize to the civil-fill stream.
Rising drive torque + missing output mass
Pause feed, reverse, tap or brush; never push harder into an unknown jam.
Torque rise with no depth progress
Stop rotation, pulse percussion, reverse and withdraw in staged increments.
LiDAR, visual odometry and wheel state disagree
Stow tools, stop, relocalize against beacons or request a new Earth-approved plan.
Forecast reserve or component limit breached
Abort the new cut, raise both drums and return to the utility pallet.
What could be sold first.
Analog field demonstrator
A rugged battery-electric quarry rover for simulant yards, mining research and material-flow pilots. Teleoperation plus supervised autonomy. No spaceflight claim.
FIRST COMMERCIALIZATION CANDIDATEFlight-derived configuration
Vacuum drives, radiation-aware avionics, dust-tolerant mechanisms, thermal survival and lander interfaces follow only after the Earth loop has moved at least 20 tonnes.
MISSION-SPECIFIC · NOT FOR SALE